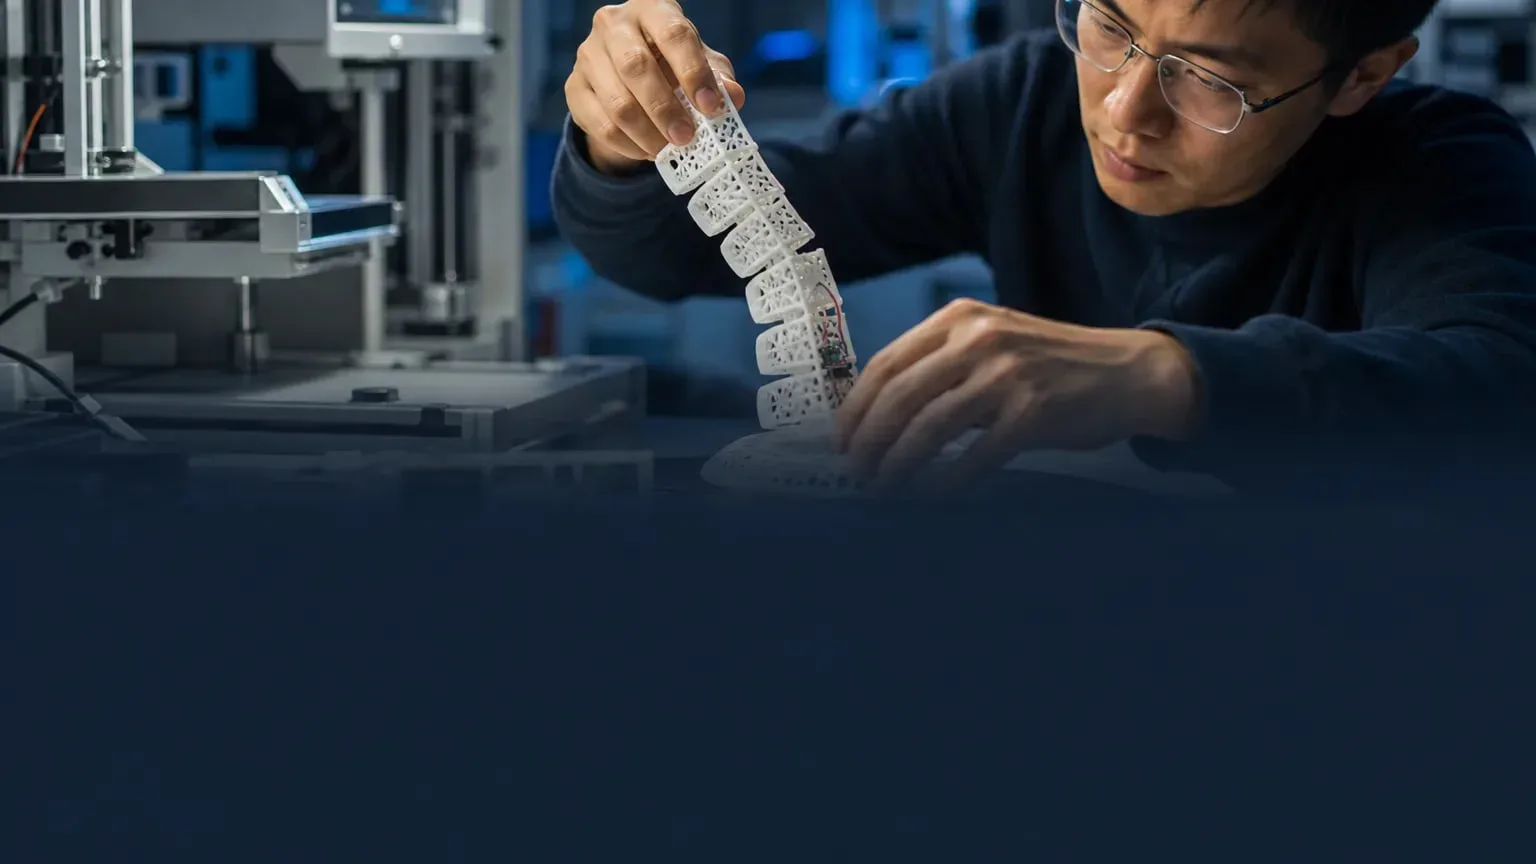
Researchers at MIT’s Computer Science and Artificial Intelligence Laboratory and Tianjin University have developed X-Hinges, a design tool that helps users 3D-print objects with built-in sensing and more precise motion tracking. The software is meant to make everyday items more interactive by embedding different materials for sensors and traces, reducing interference and allowing the printed object to perceive movement in more than one direction.
Key facts
- X-Hinges automatically embeds two different materials: one for sensors and another for wire-like traces.
- The software supports up to three axes of motion: compressing, up and down, and side to side.
- Researchers used the tool to build a glove that teaches a robot how to grasp blocks.
- They also made an origami-style lamp that changes brightness when pinched closed.
- The work will be presented at the ACM Symposium on User Interface Software and Technology in early November.
What does X-Hinges mean for students and researchers?
For students and researchers working in robotics, human-computer interaction, and digital fabrication, X-Hinges points to a way of building interactive objects that can sense motion as they are 3D-printed. The tool is designed to help creators make devices such as gloves, lamps, toys, and detection systems that respond in real time rather than relying on post-processing or added-on sensors.
The research is especially relevant to projects that need accurate motion data from deformable objects. The team says the software can support different movements in the same item and can place sensors where an object bends, such as at joints. That matters for applications like a robotic grasping glove, where captured finger motion has to be relayed quickly and reliably to another device.
The researchers also note a practical constraint: calibration. Because each printed item can vary slightly, two devices that look the same may not produce identical sensor readings. To address that, the team built a computer vision system to recalibrate outputs so the data aligns across matching devices.
How does X-Hinges work?
X-Hinges lets users assemble an object by selecting and connecting shapes, then choosing how parts should move. The software then embeds conductive materials in a way that aims to separate the sensor signal from the trace signal, which the researchers say helps avoid the interference that can make a device hard to interpret.
The tool supports a custom shape plus cylinder, rectangle, and thin outline options. It also allows designers to specify motion across three axes, which is a change from earlier approaches that often supported only one axis. In the examples described by the researchers, that flexibility helped create a cartoon shark-shaped controller with a tail that moves up and down and a lamp that reacts to a user’s pinch.
Why is signal interference such a problem?
It is a problem because sensors and traces have typically been made from the same material, which can make their signals too similar to separate cleanly. The researchers compare that challenge to hearing two radio stations at once. In practical terms, that can prevent a system from correctly interpreting how a person is moving or holding an object.
By assigning different materials to sensing and wiring functions, X-Hinges is intended to preserve stronger sensor signals and improve the device’s ability to read motion. That makes the approach useful for objects that need to respond accurately to touch, bending, or placement of an item on top of them.
What kinds of devices did the researchers make?
Using X-Hinges, the team made several prototypes that show the range of possible uses. One glove can teach a robot how to grasp blocks by recording finger-joint motion and sending that information to a humanoid hand. Another example is a small lamp that senses when it is pinched closed and changes brightness in response.
The researchers also used the software to create a system that can identify objects placed on top of it. In the example described in the work, a banana was recognized from tactile data almost immediately. The team says such object-detection systems could be useful in settings like airports and grocery stores.
What is the next step for the technology?
The researchers say they want to combine actuation and sensing in a single 3D print, rather than adding sensing after the object is made. That would extend earlier work on printed tendon-driven mechanisms and could support new embodied-intelligence platforms.
For now, the main challenge is making calibration more seamless across printed copies of the same object. The current system uses computer vision to align outputs, and the researchers hope to build a signal recalibration mechanism directly into the design process in future work.