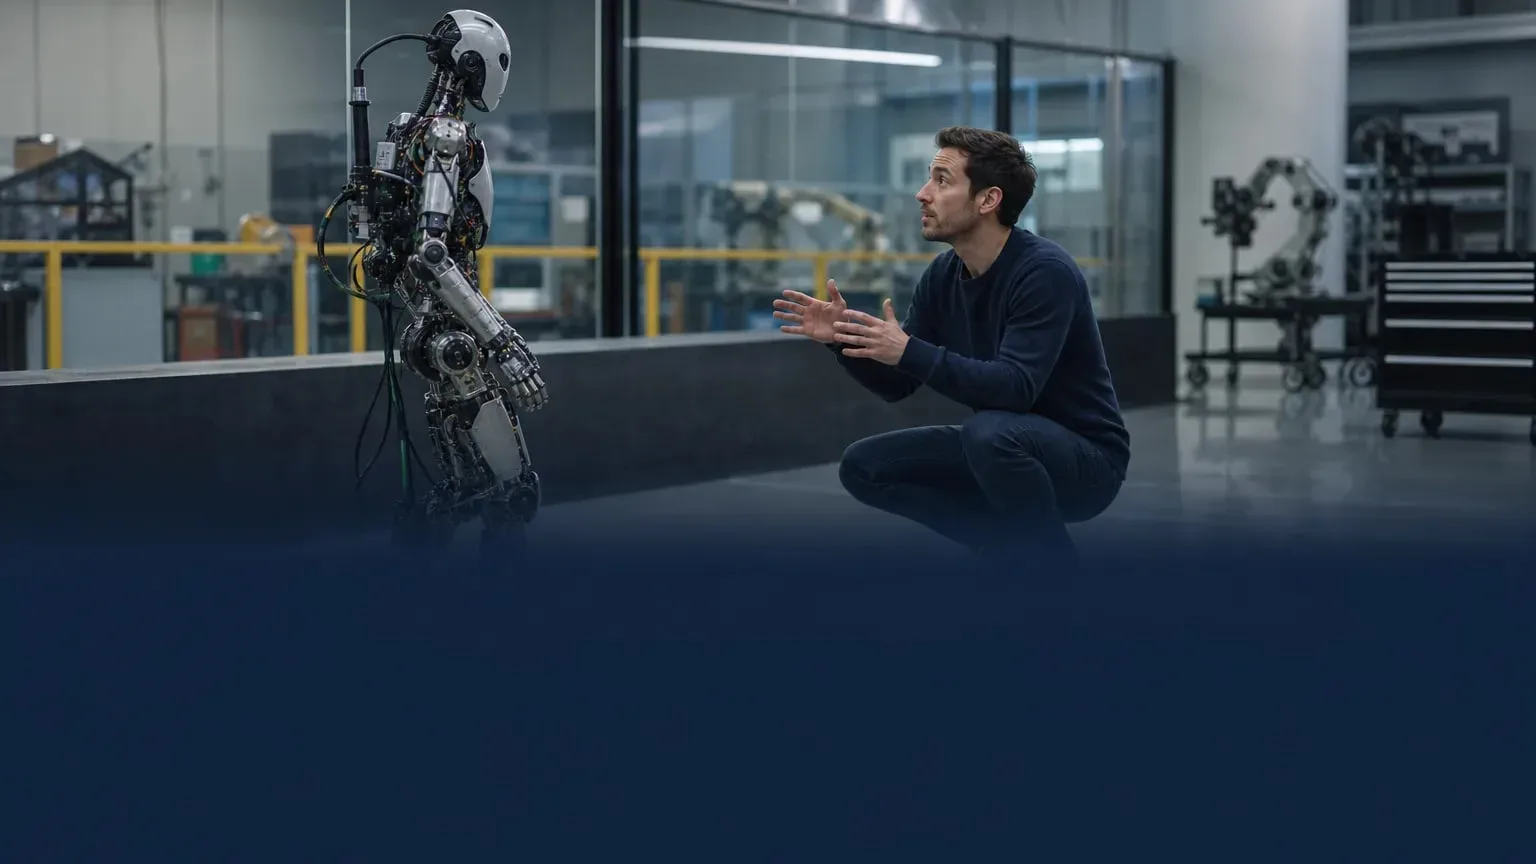
Caltech roboticist Aaron Ames says humanoid robots are advancing quickly in flashy demonstrations, but safety remains the missing piece before they can be widely deployed around people. Ames, who leads Caltech’s Center for Autonomous Systems and Technologies and works in the AMBER Lab, argues that robotics needs formal safety standards, not just impressive motion.
Key facts
- Ames says humanoid robots are being pushed toward deployment while safety is not receiving enough attention.
- He argues that without clear safety standards, someone will eventually get hurt.
- Ames helped introduce control barrier functions, a mathematical method designed to guarantee robotic safety.
- His lab at Caltech has recently applied those methods to humanoids, including collision avoidance and obstacle response.
- He says the goal is to make robots trustworthy enough to operate around people in the real world.
What this means for students and researchers working on robotics
For graduate students and postdoctoral researchers in robotics, Ames’ message is that performance alone is no longer enough. The work now extends beyond making humanoids move well and into proving they can behave safely around people, obstacles, and changing environments. In the AMBER Lab, that means coding, testing, and refining mathematical safety tools as part of everyday research.
The practical research direction highlighted in the story includes control barrier functions, reinforcement learning, and sensing tools such as LIDAR. The lab’s recent humanoid experiments include avoiding collisions, dodging a thrown ball, and stepping away from a person when it gets too close. For researchers, that points to a field where safety, control theory, and machine learning are increasingly being combined rather than treated separately.
Why is safety the main issue for humanoid robots?
Ames says the gap between controlled demonstrations and real-world deployment is still large. A robot that can flip, climb, or dance in a lab may still struggle to notice nearby people, pets, or moving obstacles in everyday settings. He argues that without mathematical safeguards, robot performance alone does not make a system safe enough for public use.
He also warns that robotics could repeat mistakes seen in autonomous vehicles, where safety failures helped derail major programs. His view is that humanoid robots need safety assurance before companies scale them widely.
How does Caltech try to make humanoid robots safer?
The core approach is control barrier functions, or CBFs, a mathematical safety layer Ames helped introduce in 2014. The method defines safe actions and can intervene between a learning-based controller and the robot’s physical motion. In practice, that means performance-focused AI can keep learning, while the safety filter keeps the robot within defined limits.
At Caltech, Ames’ lab has tested those ideas on humanoids and other robots. Recent work described in the story includes using CBFs with reinforcement learning to avoid collisions and adding sensors that help robots map nearby objects and move safely in dynamic environments.
What is the immediate future of humanoid safety?
Ames says the near-term path is combining established control methods with modern AI, rather than relying on learning systems alone. He says machine learning can help optimize performance, but it cannot by itself prove that a robot will never take an unsafe action. For him, the solution is mathematical rigor backed by physics, theorems, and testable guarantees.
That approach, he says, is what could make humanoid robots useful in the real world while still protecting people around them.